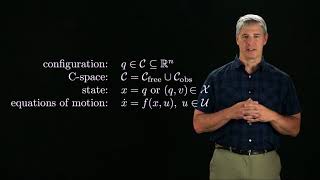
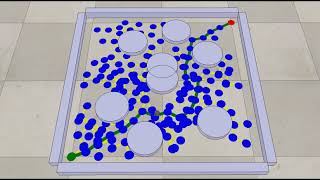
Background on Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2
Looking for the latest information on Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2? We've compiled comprehensive data, records, and insights about Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2.
Core Information
Explore the main sources for Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2.
History
Stay updated on Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2's latest milestones.
Modern Robotics, Chapter 10.1: Overview of Motion Planning
Motion Planning - RRT Sampling method
Tutorial 4: Sampling-based Motion Planning - Day 2 - Tuesday, July 24
Modern Robotics, Chapter 10.4: Grid Methods for Motion Planning
Sample Based Motion Planning(Part-1): Lecture-12
Modern Robotics, Chapter 10.2: C-Space Obstacles
Sampling-based Motion Planning for Active Multirotor System Identification
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 20, 2026
Summary
For 2026, Modern Robotics Chapter 10 5 Sampling Methods For Motion Planning Part 1 Of 2 remains one of the most searched-for information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.