Overview on Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step
Looking for the latest information on Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step? We've compiled comprehensive data, records, and insights about Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step.
Core Information
Explore the primary sources for Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step.
Developments
Stay updated on Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step's latest milestones.
Rapidly-exploring random trees algorithm demo
RRT* Algorithm Explained
Rapidly-exploring Random Tree [RRT] Algorithm Implementation in Python | Robotics
RRT (Rapidly-Exploring Random Trees) C++
RRT* Finding a Path
Introduction to Motion Planning Algorithms | Motion Planning with the RRT Algorithm, Part 1
Rapidly Exploring Random Trees | RRT | Code + Description | Python
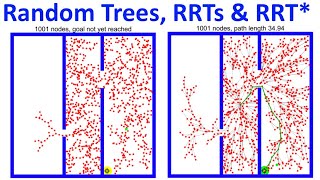
Sampling Based Path Planning: Rapidly Exploring Random Trees (RRT)
Randomly Exploring Random Trees - RRt
3D RRT* Implementation
RRT: Rapidly Exploring Random Trees | UCSD | ECE Robotics |
Detailed Analysis
Data is compiled from public records and verified media reports.
Last Updated: September 20, 2026
Summary
For 2026, Motion Planning Rapidly Exploring Random Trees Rrt Algorithm Implementation Step By Step remains one of the most talked-about information profiles. Check back for the newest reports.
Disclaimer: Disclaimer: All information is compiled from publicly available data, media reports, and analysis. Actual details may vary.